






Scientific computing · data assimilation · perception systems.
I build software that connects physical models, sparse observations, and reconstruction — and the engineering around that: cameras, control loops, and research tools that actually run.
MSc (2025), University of Calgary. Computer engineering before that.
LinkedIn · GitHub · Scholar · Thesis · Portfolio · X · Index
| # | Repo | What you will actually find |
|---|---|---|
| 1 | qg-lada-lab | Spectral QG twin + localized EnKF in the browser, plus a committed Python solver. Demo-scale XCOR 0.964 on N = 32 (not the thesis table). Live |
| 2 | axis-vision-pan-tilt | Vision → UART → STM32 STEP/DIR. Software verified. Hardware not bench-tested. Live |
| 3 | local_wccm | MATLAB working copy of the barotropic Lagrangian filter (lagrangianfilter_baro.m, spectra, drivers). |
| 4 | ai-perception-lab | Local-first camera workstation. Real COCO-SSD in the browser. Simulated fleet KPIs are labeled. |
| 5 | computer_Architecture_Project_Piplined-_CPU_2021 | Verilog pipelined MIPS: forwarding, stall, flush, testbench. Student CPU. |
| 6 | meridian | Research terminal. Ranks papers and artifacts by technical depth, not virality. Live |
| 7 | lattice | Visual field manual of machine intelligence. Original live product. Live |
GitHub pins max out at six — pin 1–6. lattice is seventh here because it is original and live, but it is not the thesis or the control stack.
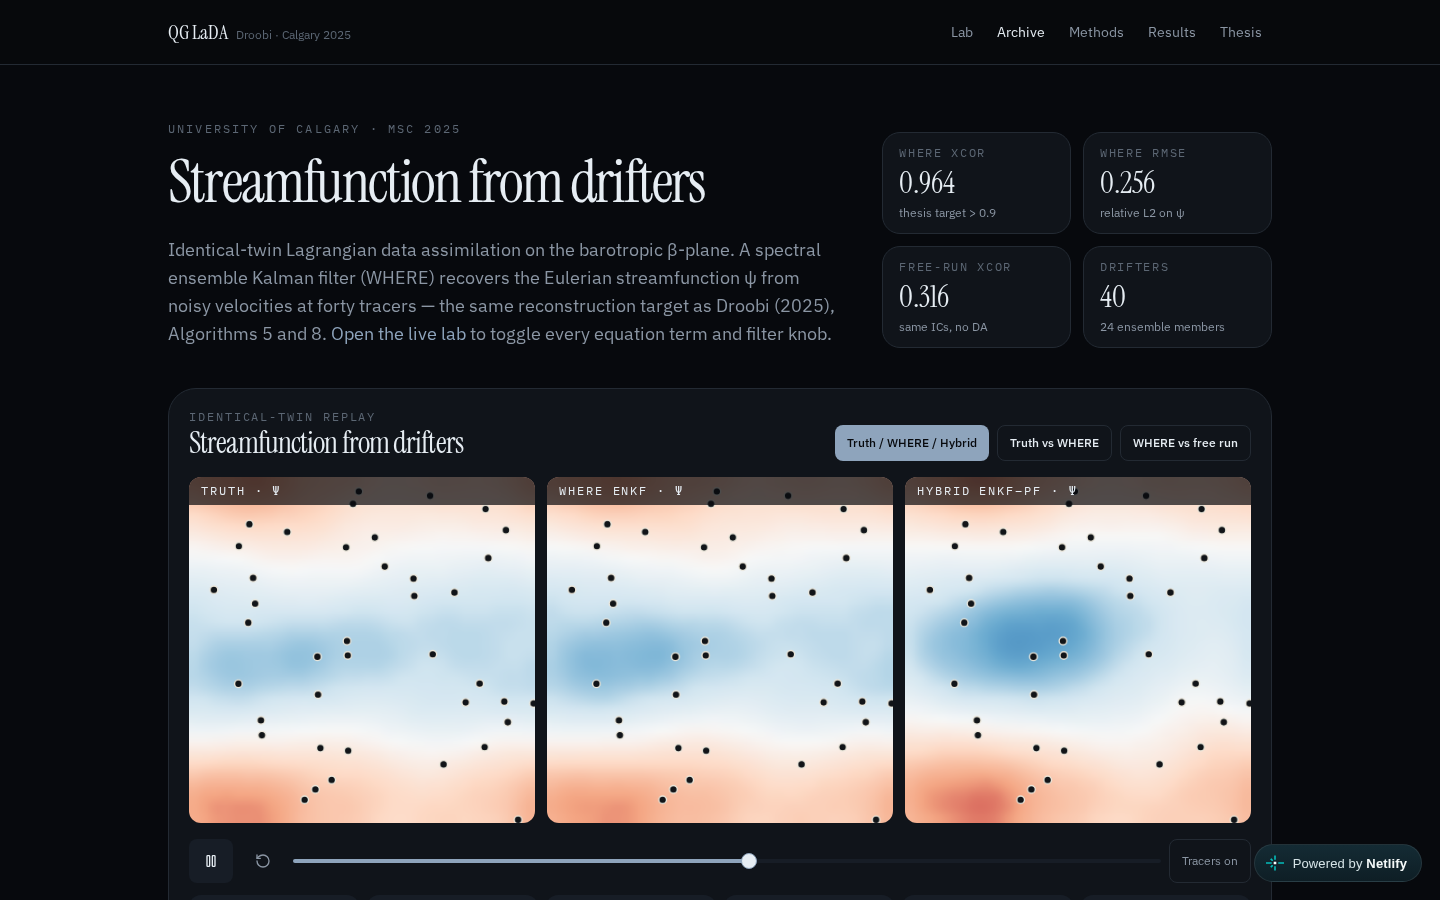
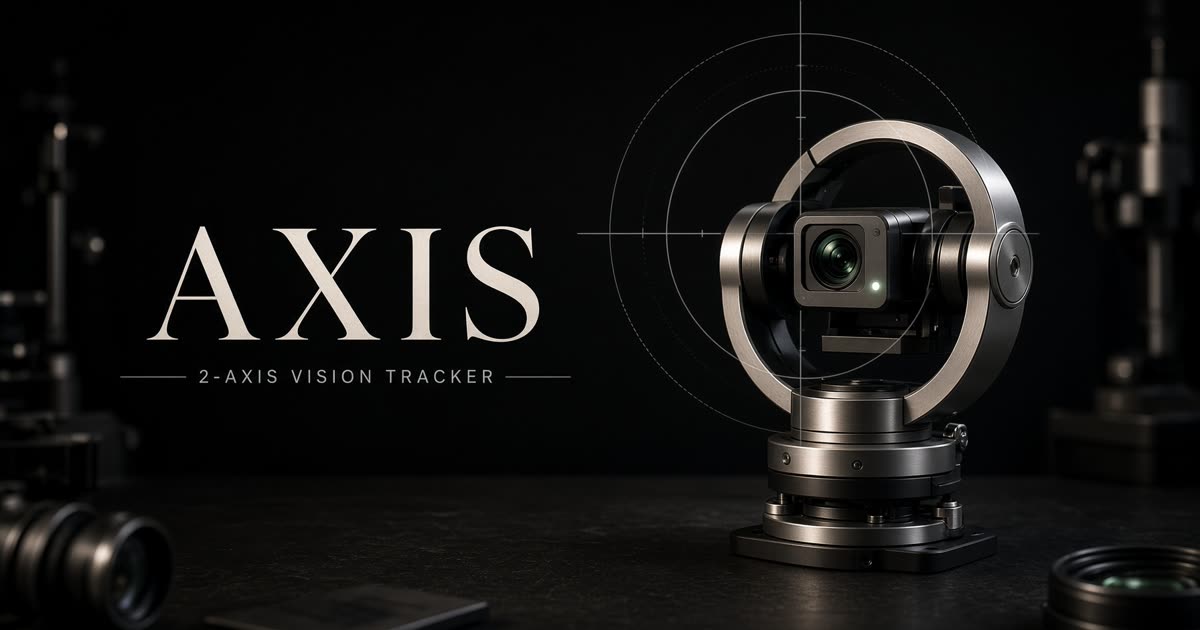
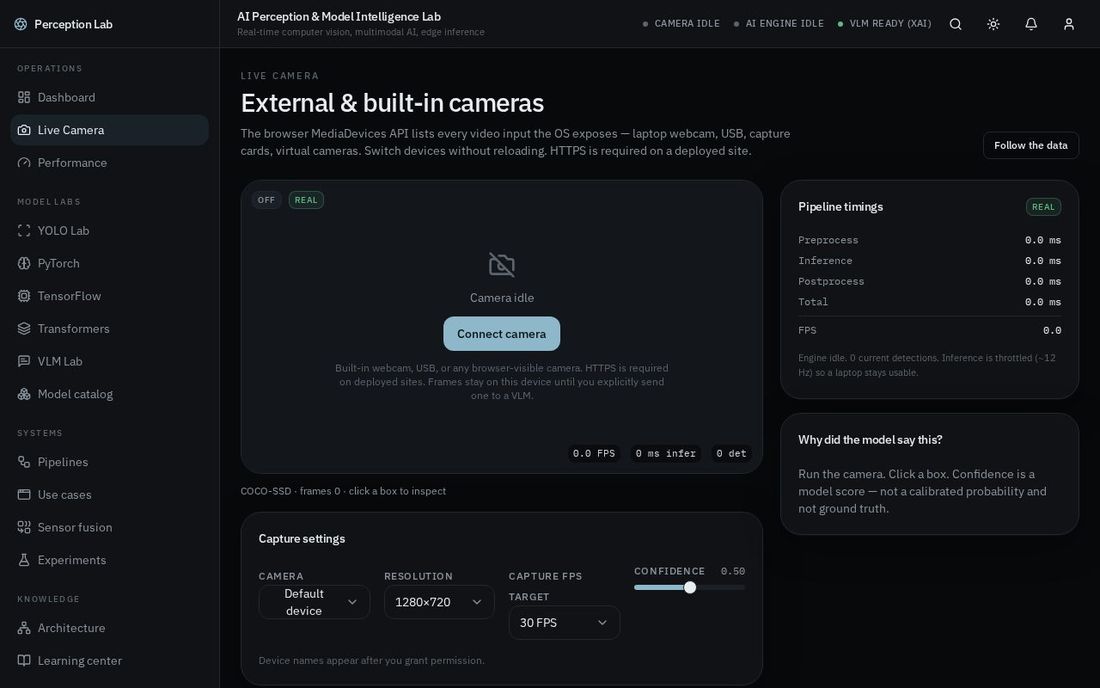
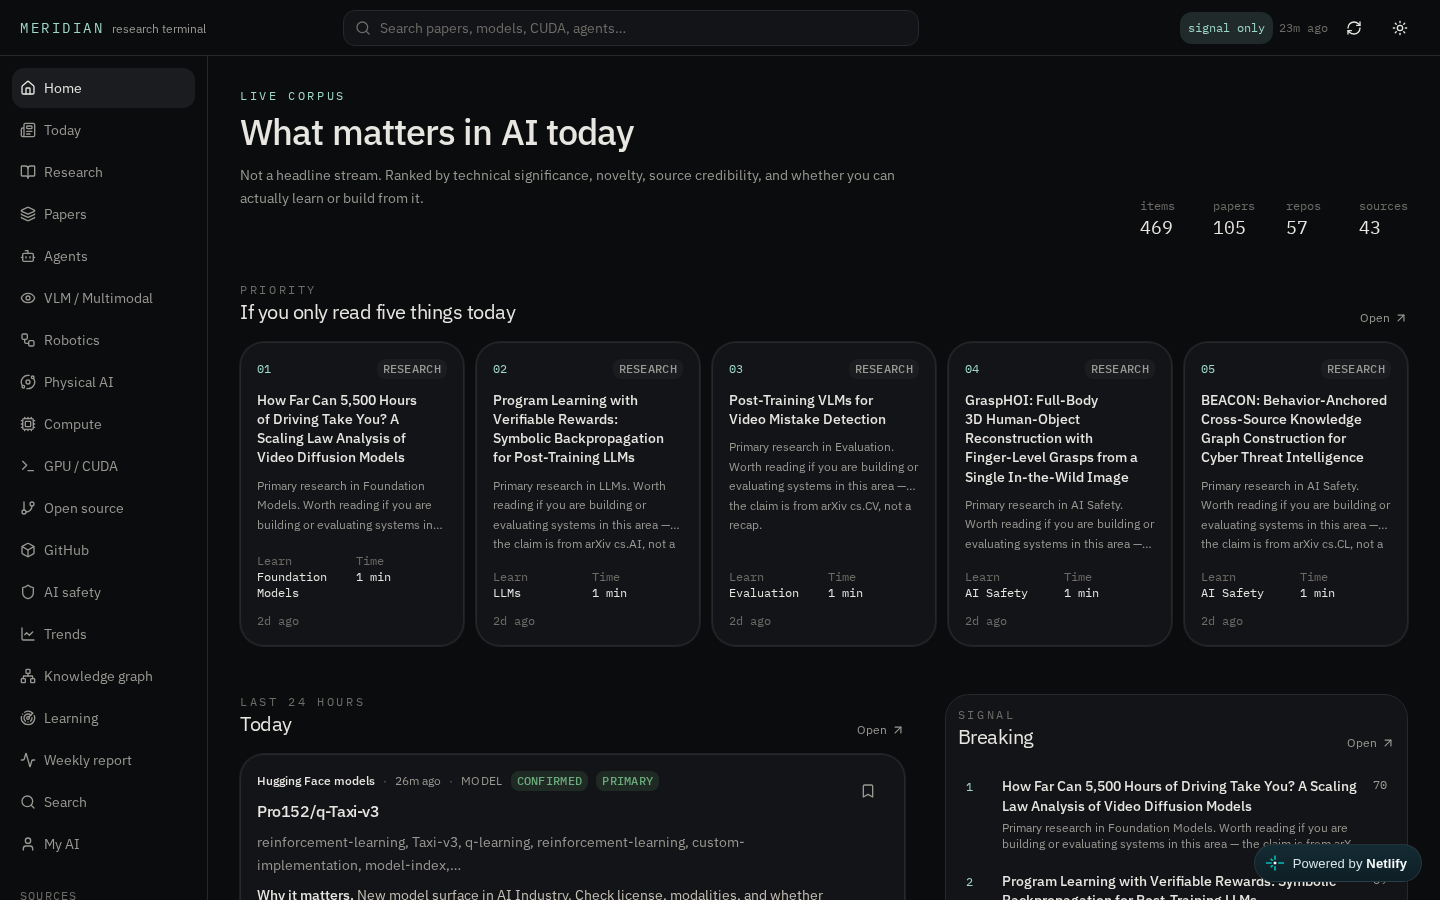
Live captures. Not mockups.
Hardware / sensors
        ↓
Real-time software
        ↓
Estimation / control / filters
        ↓
Simulation + visualization
        ↓
Research software that runs
Lagrangian drifters  →  QG barotropic model (q = ∇²ψ − μψ)
                     →  spectral Helmholtz inversion
                     →  localized stochastic EnKF  (+ optional EnKF–PF)
                     →  reconstructed Eulerian field, spectra, XCOR
Thesis: Data-Driven Filtering Techniques for Turbulent Flow Models (A Lagrangian Data Assimilation Approach) (Scholaris). Private thesis sources stay private.
GitHub cannot custom-sort the Repositories tab. This profile is the catalog: research first, undergraduate last. Homework from 2020–2022 is archived. Same grouping: projects.
Public research lab for Lagrangian data assimilation, a software-verified vision pan/tilt control stack, and perception tooling. Looking for engineering roles where models, sensors, and software have to meet.
Perception / control. vla-drive-sim is a pedagogical driving loop (language selects a path; vision is heading error; PD emits actions). Not a trained VLA.
Research software. engineering-portfolio · world-pulse
Maps / study notes. Catalogs and seminar reconstructions (found-300, 36-key-cv-topics, robot-data-gap-gofe, and similar) are reading maps. They are not implementations. See the index.
Experiments. Honest about what is committed: ridgeflight, tensortonic-rag-from-scratch, mosqguard, forge-mind, aws-from-scratch, aetherforge (no src/ yet), stackforge (scaffold only).
BSc Computer Engineering, An-Najah National University, 2023. Provenance, not current work.
- seniorGraduationProject2022_cookOverflow — Django recipe site + recommender R&D
- cookoverflow_Mobile_GradProject_2022 — Flutter client
- SoftwareProject_2021_Agile_Trello — PayMe Java Swing e-wallet (not Trello)
- Messnger_FileTransfer_StopAndWaitProtocol_UDP — Java UDP + Stop-and-Wait 3.0
- Data assimilation — EnKF, particle filters, hybrid EnKF–PF, localization, inflation, Lagrangian observations
- Geophysical models — barotropic QG, shallow-water, Lorenz-63 / L96 as reduced-order tests
- Scientific computing — spectral methods, Helmholtz inversion, Python and MATLAB
- Uncertainty quantification — filtering, stochastic forcing, spectra, reconstruction skill
- Perception and control design — camera pipelines, in-browser detection, UART protocol, PID with safety interlocks (software-verified)
- Software — Python, TypeScript/React, MATLAB, Verilog, experiments other people can rerun
Forks of DAPPER, PyDA, torchda, and similar are reference, not original work.
- MSc, University of Calgary, 2025 — scientific ML / Lagrangian DA / UQ
- BSc Computer Engineering, An-Najah National University, 2023